
Real-Time Optimal Control of Connected and Automated Vehicles
Connectivity tells an automated vehicle what the signals and traffic ahead will do. We design controllers that use this preview to drive more efficiently and smoothly, account for how electric, gasoline and hybrid powertrains use energy, and run fast enough for real time.
Read More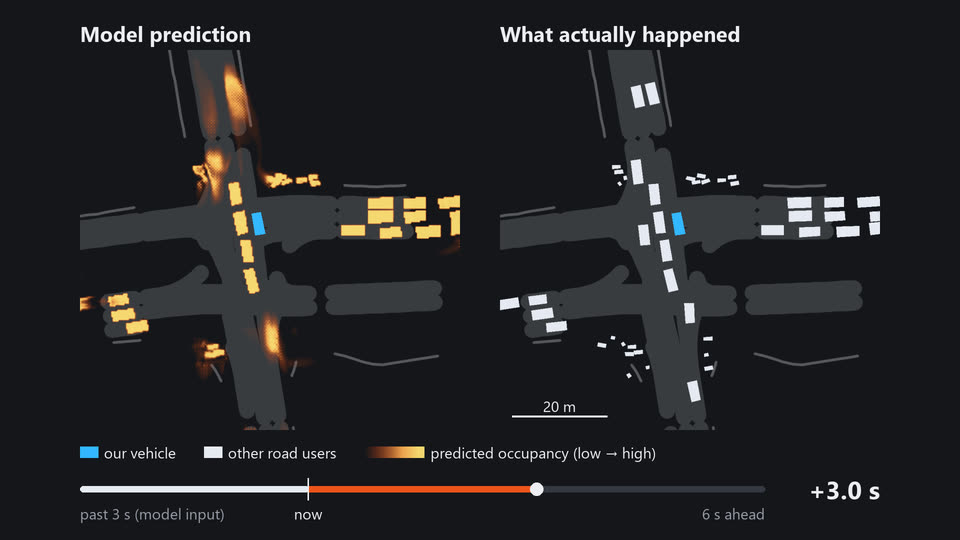
Traffic Prediction for Control
Controllers need to know what traffic ahead will do. We combine learned occupancy-flow prediction for the next few seconds with queue and traffic-flow models for longer horizons, using connected vehicles, signal timing and neighbouring road segments.
Read More
X-in-the-loop (XIL) Evaluation
Connected and automated vehicle technologies need thorough testing before they reach real roads. X-in-the-loop simulation connects real hardware, such as a vehicle on a chassis dynamometer or a signal controller, with traffic and vehicle simulators and 3D environments, so the actual response of the physical system is tested in repeatable, high-fidelity scenarios. Our Real-Sim framework and its open-source interface, FIXS, make these connections plug-and-play.
Read More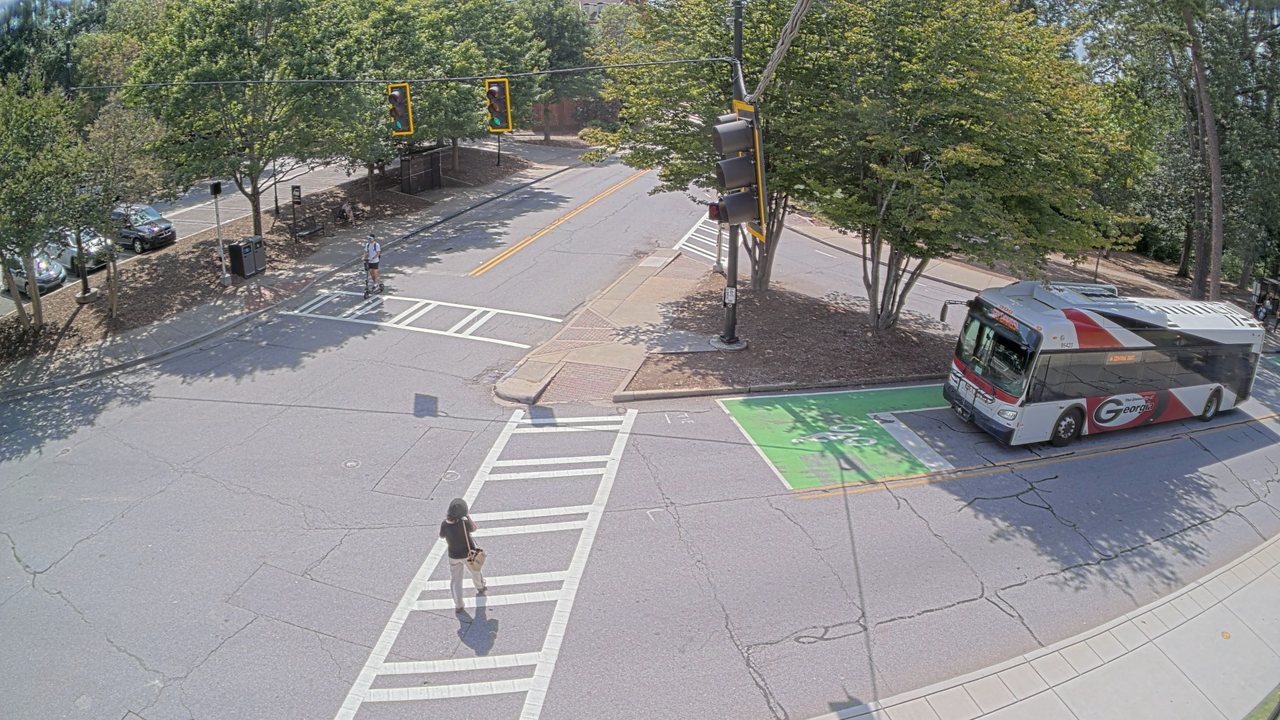
Living Lab for Smart Intersections
A working campus intersection that we watch and measure live. A panoramic traffic camera and an edge computer at Sanford Drive and Cedar Street stream to our lab, where every car, bus, bike and person is tracked: live view, replay, safety-critical events, turning movements and signal performance. The same live feed is our test bed for trajectory prediction, driver warnings and signal timing, and the platform is built to extend to more sites.
Read More