Real-Time Optimal Control of Connected and Automated Vehicles
Connectivity tells an automated vehicle what the signals and traffic ahead will do. We design controllers that use this preview to drive more efficiently and smoothly, account for how each powertrain uses energy, and run fast enough for real time.
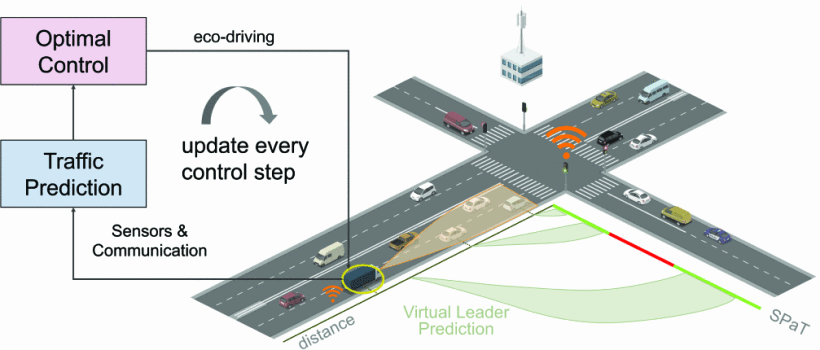
Traffic prediction and optimal control, updated every control step. Prediction methods: traffic prediction. [2]
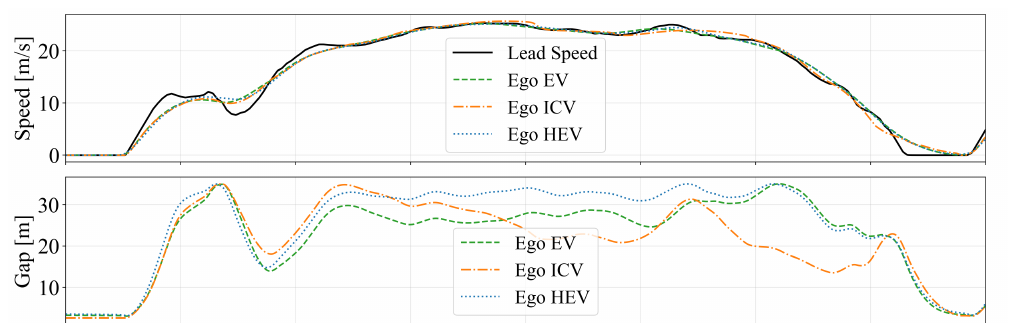
Electric, gasoline and hybrid vehicles under the same controller, following the same lead vehicle: speed (top) and gap to the lead vehicle (bottom). [1]
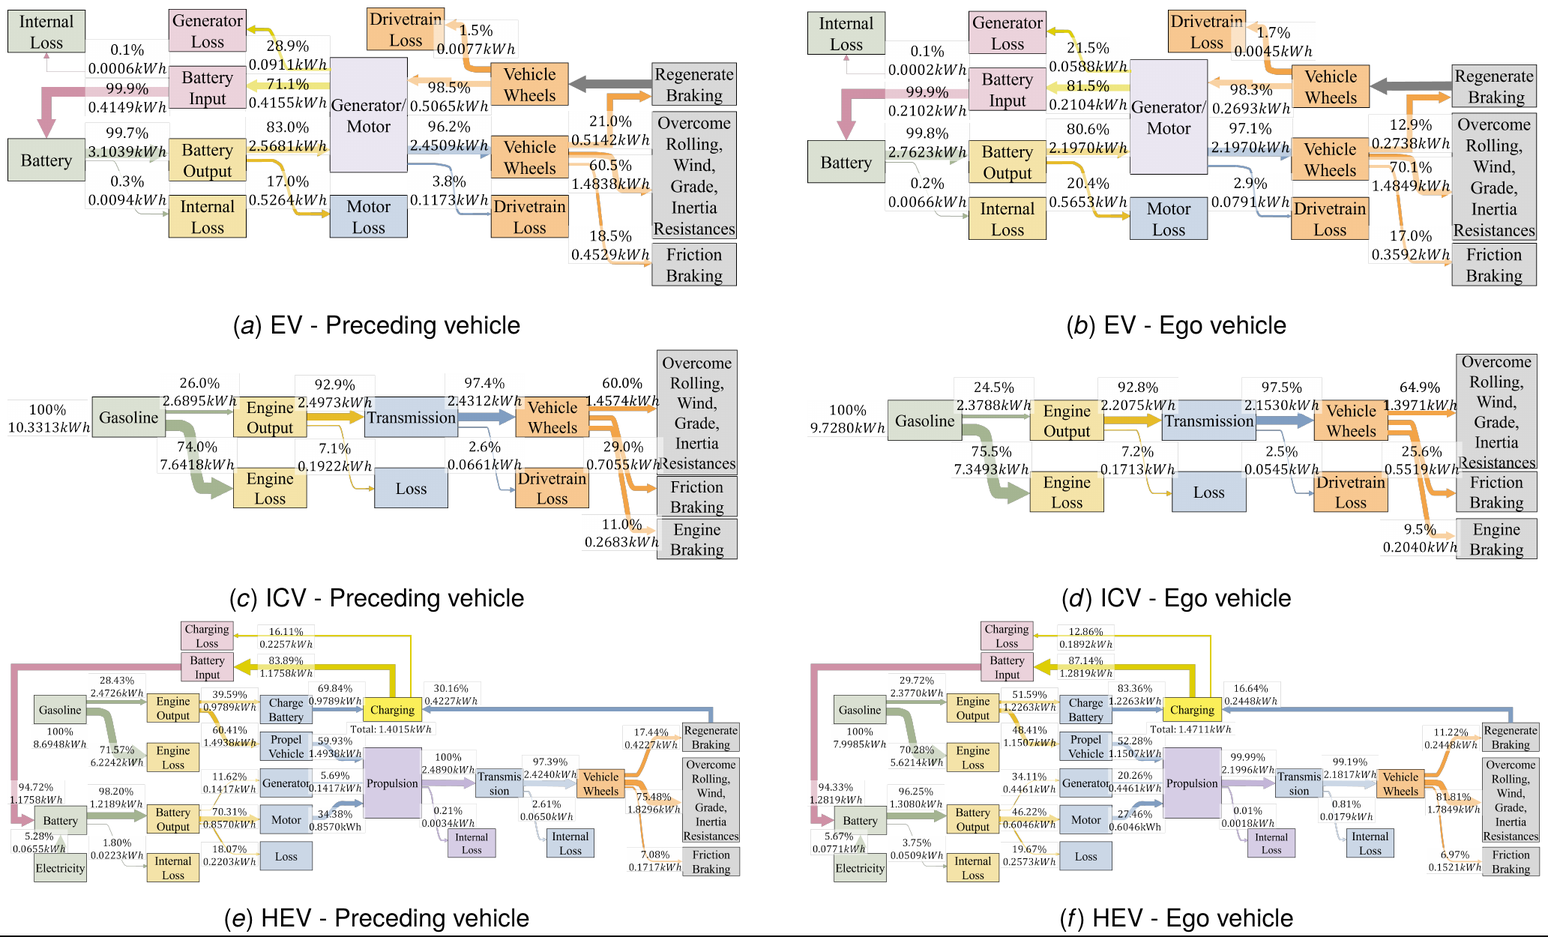
Energy flow of electric (top), gasoline (middle) and hybrid (bottom) vehicles following the same lead vehicle, without (left) and with (right) optimal control. [1]
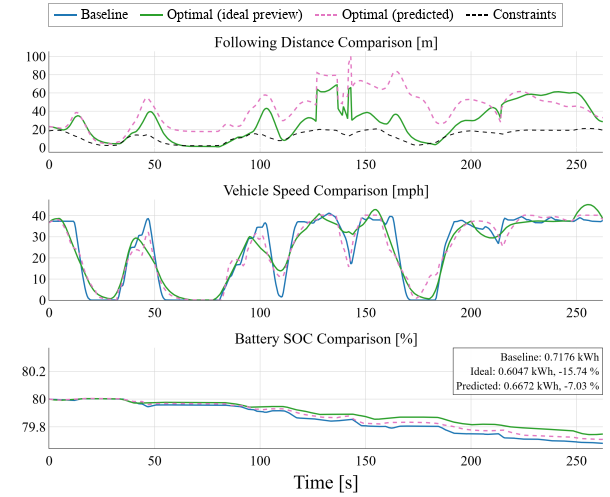
Following distance, speed and battery state of charge on an eight-signal corridor in simulation, controlled vehicle vs the original vehicle. [2]
Co-simulation through FIXS: SUMO traffic, CARLA 3D view and the vehicle state exchanged in real time.
Publications
- Y. Gao and Y. Shao, "Energy flow analysis of automated vehicles under a unified powertrain framework," ASME Letters in Dynamic Systems and Control, 2026 (accepted).
- Y. Shao, "Computationally efficient energy-optimal control of automated vehicles with virtual leader prediction in urban traffic," ACC, 2026.
- Y. Shao and Z. Sun, "Eco-approach with traffic prediction and experimental validation for connected and autonomous vehicles," IEEE Trans. ITS, 22(3), 2021.
- Y. Shao and Z. Sun, "Energy-efficient connected and automated vehicles: real-time traffic prediction-enabled co-optimization of vehicle motion and powertrain operation," IEEE Vehicular Technology Magazine, 16(3), 2021.