X-in-the-loop Evaluation of Connected and Automated Vehicles
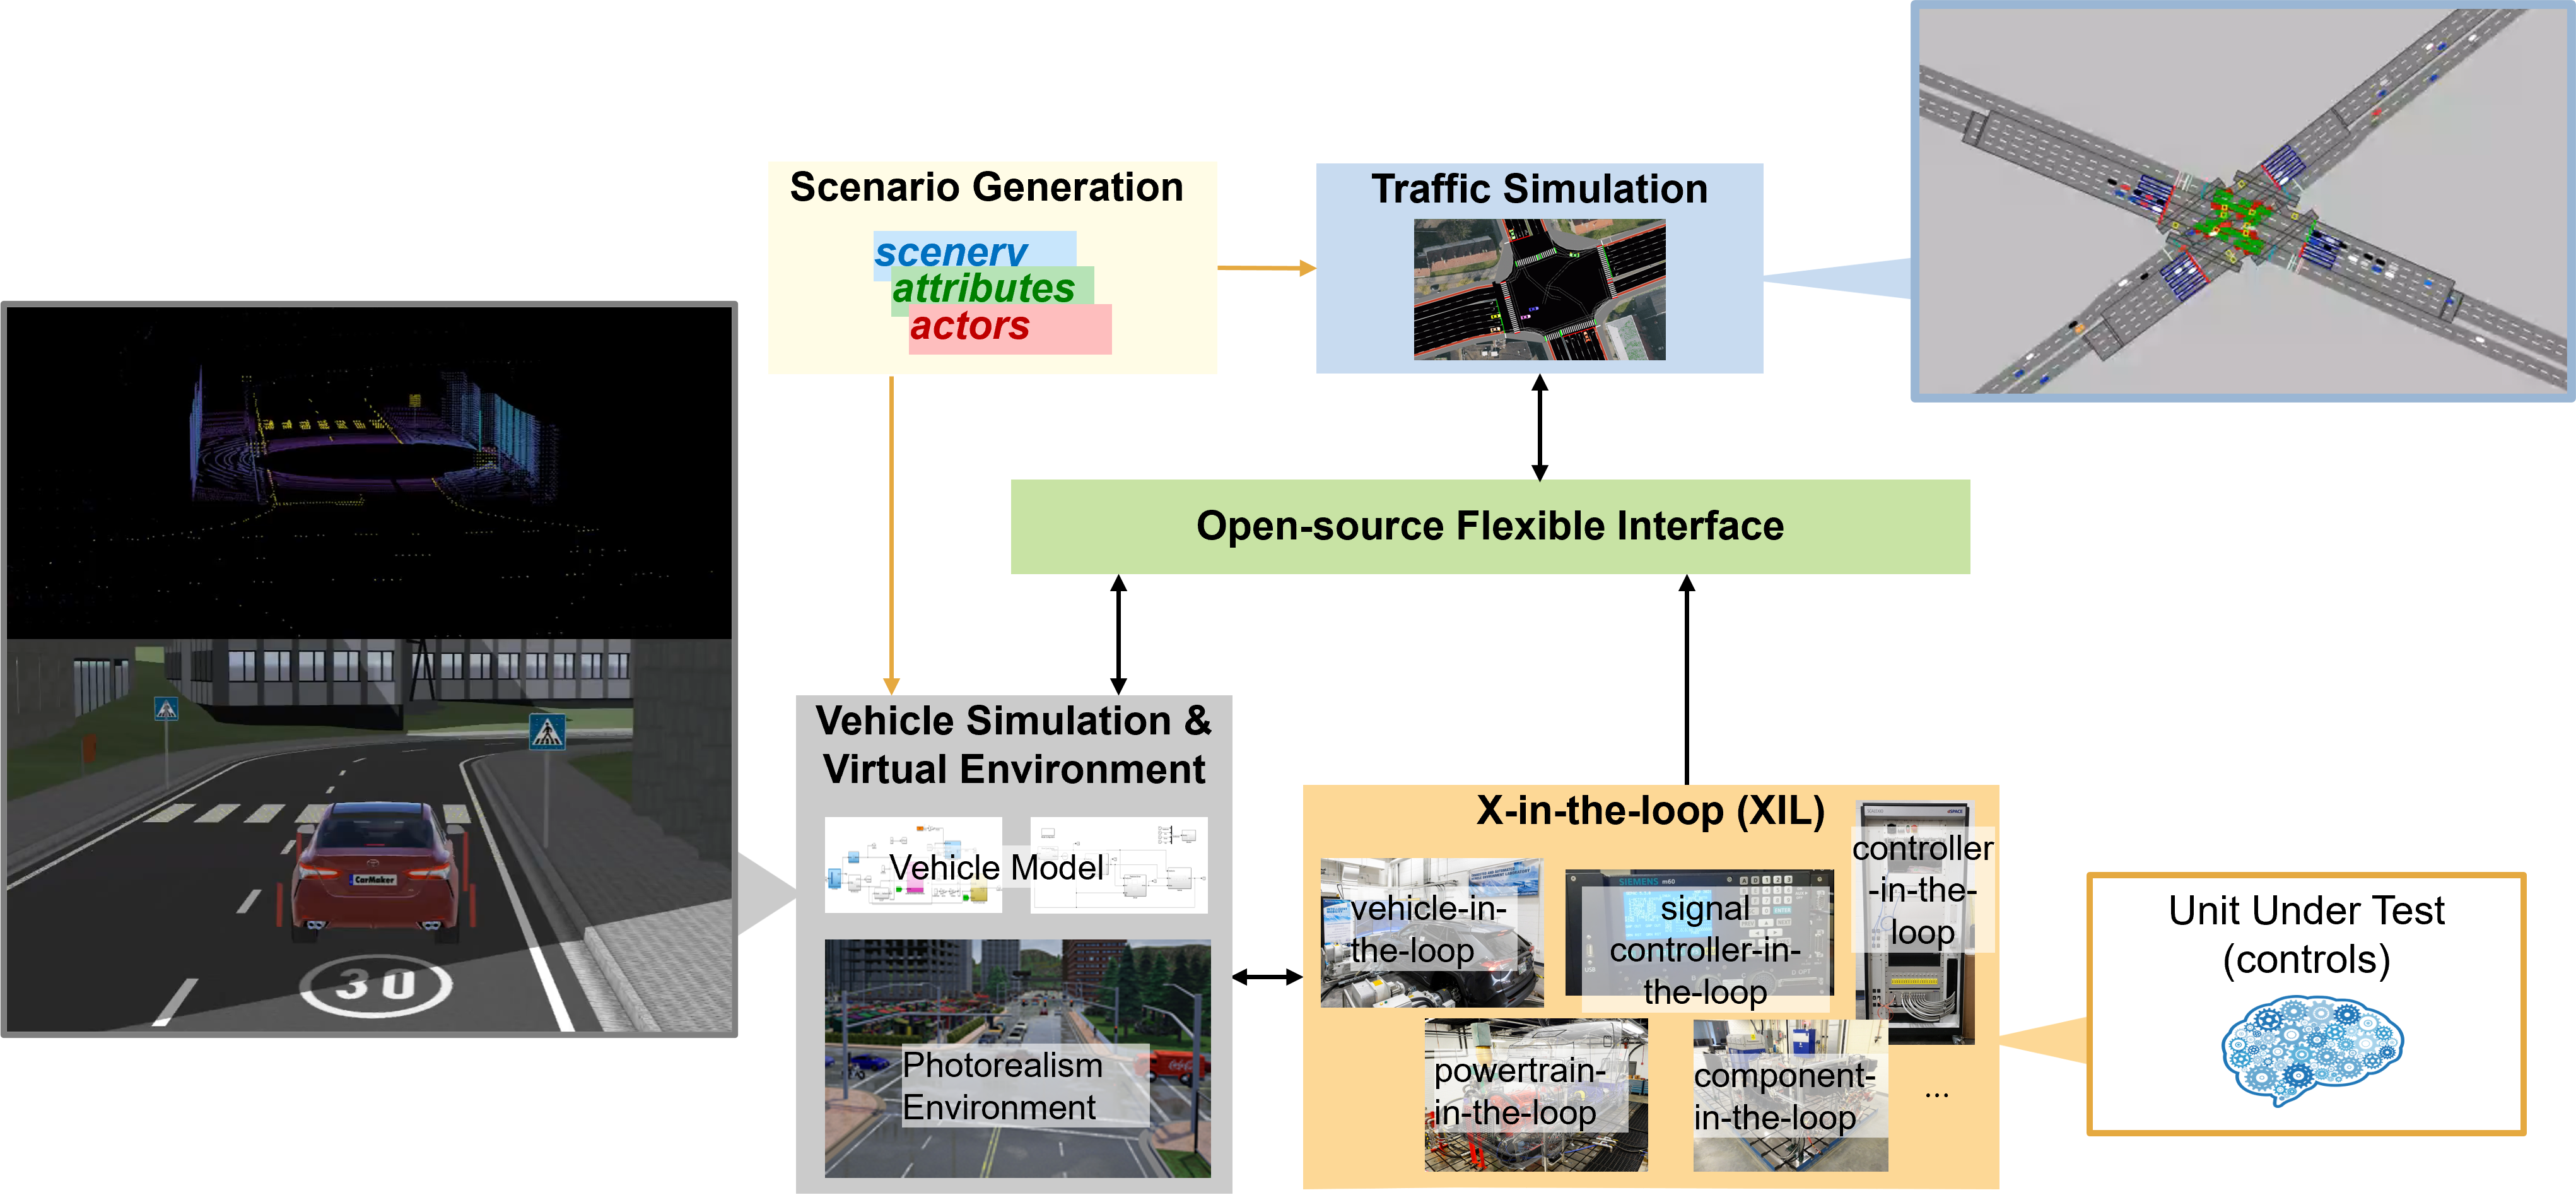
Connected and automated vehicle (CAV) technologies need comprehensive testing and evaluation before they reach real roads. Because CAVs span the vehicle, traffic and infrastructure, this calls for a platform that brings together vehicle and traffic simulation tools from different domains with X-in-the-loop (XIL) components. Real-Sim is a multi-resolution XIL simulation framework for inclusive testing and evaluation of CAVs. It is funded by the U.S. Department of Energy's Energy Efficient Mobility Systems (EEMS) program and led by Oak Ridge National Laboratory, with the University of Georgia and the University of Texas at Dallas.
SUMO + CARLA + EcoPilot + vehicle-in-the-loop
A real vehicle on a chassis dynamometer drives through SUMO traffic, shown in the CARLA 3D environment, while EcoPilot gives energy-efficient speed advice.
A flexible interface handles the connections, so co-simulation of vehicle and traffic simulation tools with different XIL systems becomes a transparent “plug-and-play” process. Real-Sim also emulates perception sensors and communication to test advanced driver-assistance systems, automated driving systems and connected vehicle technologies. The Flexible Interface for X-in-the-loop Simulation (FIXS) is open source on GitHub, and more demos are at ORNL-Real-Sim.